RoboParty Debuts RP1 Full-Stack Open-Source Humanoid Robot at IROS 2026
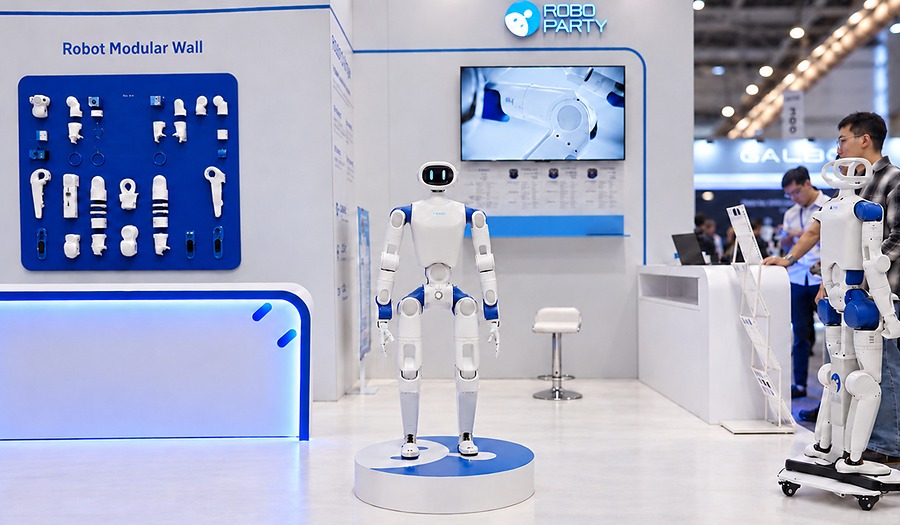
According to reporting from Engineering.com, RoboParty has introduced a new bipedal platform designed to grant developers deep access to both hardware and software layers. The RP1 humanoid utilizes a reinforcement learning framework to manage balance and recovery, moving away from the rigid, predefined motion paths that characterize many proprietary robotics systems.
Context from Industry Pulse
The introduction of the RP1 follows a surge in experimental robotics, ranging from recent advancements in dexterous soft grippers to new rare-earth-free magnetic drives for military applications. While many high-performance humanoids remain locked within proprietary ecosystems, RoboParty is pivoting toward a transparent development model that includes everything from joint actuators to simulation environments. This shift mirrors broader engineering trends where open-source frameworks are used to accelerate complex testing, such as the grid-integration of electric vehicles. Engineers should monitor the upcoming Q4 mass-production roadmap to see if open-source hardware can match the reliability of established, closed-loop industrial platforms.
The Industry Pulse Bottom Line
By releasing the underlying Romomo actuator specs and PartyOS source code, RoboParty is betting that community-driven iteration will solve the stability hurdles that currently stall humanoid deployment in unpredictable real-world environments.